
6.10: Determining Volumes by Slicing
- Page ID
- 175575
\( \newcommand{\vecs}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\( \newcommand{\vecd}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash {#1}}} \)
\( \newcommand{\dsum}{\displaystyle\sum\limits} \)
\( \newcommand{\dint}{\displaystyle\int\limits} \)
\( \newcommand{\dlim}{\displaystyle\lim\limits} \)
\( \newcommand{\id}{\mathrm{id}}\) \( \newcommand{\Span}{\mathrm{span}}\)
( \newcommand{\kernel}{\mathrm{null}\,}\) \( \newcommand{\range}{\mathrm{range}\,}\)
\( \newcommand{\RealPart}{\mathrm{Re}}\) \( \newcommand{\ImaginaryPart}{\mathrm{Im}}\)
\( \newcommand{\Argument}{\mathrm{Arg}}\) \( \newcommand{\norm}[1]{\| #1 \|}\)
\( \newcommand{\inner}[2]{\langle #1, #2 \rangle}\)
\( \newcommand{\Span}{\mathrm{span}}\)
\( \newcommand{\id}{\mathrm{id}}\)
\( \newcommand{\Span}{\mathrm{span}}\)
\( \newcommand{\kernel}{\mathrm{null}\,}\)
\( \newcommand{\range}{\mathrm{range}\,}\)
\( \newcommand{\RealPart}{\mathrm{Re}}\)
\( \newcommand{\ImaginaryPart}{\mathrm{Im}}\)
\( \newcommand{\Argument}{\mathrm{Arg}}\)
\( \newcommand{\norm}[1]{\| #1 \|}\)
\( \newcommand{\inner}[2]{\langle #1, #2 \rangle}\)
\( \newcommand{\Span}{\mathrm{span}}\) \( \newcommand{\AA}{\unicode[.8,0]{x212B}}\)
\( \newcommand{\vectorA}[1]{\vec{#1}} % arrow\)
\( \newcommand{\vectorAt}[1]{\vec{\text{#1}}} % arrow\)
\( \newcommand{\vectorB}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\( \newcommand{\vectorC}[1]{\textbf{#1}} \)
\( \newcommand{\vectorD}[1]{\overrightarrow{#1}} \)
\( \newcommand{\vectorDt}[1]{\overrightarrow{\text{#1}}} \)
\( \newcommand{\vectE}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash{\mathbf {#1}}}} \)
\( \newcommand{\vecs}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\(\newcommand{\longvect}{\overrightarrow}\)
\( \newcommand{\vecd}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash {#1}}} \)
\(\newcommand{\avec}{\mathbf a}\) \(\newcommand{\bvec}{\mathbf b}\) \(\newcommand{\cvec}{\mathbf c}\) \(\newcommand{\dvec}{\mathbf d}\) \(\newcommand{\dtil}{\widetilde{\mathbf d}}\) \(\newcommand{\evec}{\mathbf e}\) \(\newcommand{\fvec}{\mathbf f}\) \(\newcommand{\nvec}{\mathbf n}\) \(\newcommand{\pvec}{\mathbf p}\) \(\newcommand{\qvec}{\mathbf q}\) \(\newcommand{\svec}{\mathbf s}\) \(\newcommand{\tvec}{\mathbf t}\) \(\newcommand{\uvec}{\mathbf u}\) \(\newcommand{\vvec}{\mathbf v}\) \(\newcommand{\wvec}{\mathbf w}\) \(\newcommand{\xvec}{\mathbf x}\) \(\newcommand{\yvec}{\mathbf y}\) \(\newcommand{\zvec}{\mathbf z}\) \(\newcommand{\rvec}{\mathbf r}\) \(\newcommand{\mvec}{\mathbf m}\) \(\newcommand{\zerovec}{\mathbf 0}\) \(\newcommand{\onevec}{\mathbf 1}\) \(\newcommand{\real}{\mathbb R}\) \(\newcommand{\twovec}[2]{\left[\begin{array}{r}#1 \\ #2 \end{array}\right]}\) \(\newcommand{\ctwovec}[2]{\left[\begin{array}{c}#1 \\ #2 \end{array}\right]}\) \(\newcommand{\threevec}[3]{\left[\begin{array}{r}#1 \\ #2 \\ #3 \end{array}\right]}\) \(\newcommand{\cthreevec}[3]{\left[\begin{array}{c}#1 \\ #2 \\ #3 \end{array}\right]}\) \(\newcommand{\fourvec}[4]{\left[\begin{array}{r}#1 \\ #2 \\ #3 \\ #4 \end{array}\right]}\) \(\newcommand{\cfourvec}[4]{\left[\begin{array}{c}#1 \\ #2 \\ #3 \\ #4 \end{array}\right]}\) \(\newcommand{\fivevec}[5]{\left[\begin{array}{r}#1 \\ #2 \\ #3 \\ #4 \\ #5 \\ \end{array}\right]}\) \(\newcommand{\cfivevec}[5]{\left[\begin{array}{c}#1 \\ #2 \\ #3 \\ #4 \\ #5 \\ \end{array}\right]}\) \(\newcommand{\mattwo}[4]{\left[\begin{array}{rr}#1 \amp #2 \\ #3 \amp #4 \\ \end{array}\right]}\) \(\newcommand{\laspan}[1]{\text{Span}\{#1\}}\) \(\newcommand{\bcal}{\cal B}\) \(\newcommand{\ccal}{\cal C}\) \(\newcommand{\scal}{\cal S}\) \(\newcommand{\wcal}{\cal W}\) \(\newcommand{\ecal}{\cal E}\) \(\newcommand{\coords}[2]{\left\{#1\right\}_{#2}}\) \(\newcommand{\gray}[1]{\color{gray}{#1}}\) \(\newcommand{\lgray}[1]{\color{lightgray}{#1}}\) \(\newcommand{\rank}{\operatorname{rank}}\) \(\newcommand{\row}{\text{Row}}\) \(\newcommand{\col}{\text{Col}}\) \(\renewcommand{\row}{\text{Row}}\) \(\newcommand{\nul}{\text{Nul}}\) \(\newcommand{\var}{\text{Var}}\) \(\newcommand{\corr}{\text{corr}}\) \(\newcommand{\len}[1]{\left|#1\right|}\) \(\newcommand{\bbar}{\overline{\bvec}}\) \(\newcommand{\bhat}{\widehat{\bvec}}\) \(\newcommand{\bperp}{\bvec^\perp}\) \(\newcommand{\xhat}{\widehat{\xvec}}\) \(\newcommand{\vhat}{\widehat{\vvec}}\) \(\newcommand{\uhat}{\widehat{\uvec}}\) \(\newcommand{\what}{\widehat{\wvec}}\) \(\newcommand{\Sighat}{\widehat{\Sigma}}\) \(\newcommand{\lt}{<}\) \(\newcommand{\gt}{>}\) \(\newcommand{\amp}{&}\) \(\definecolor{fillinmathshade}{gray}{0.9}\)- Note to the Instructor (click to expand)
- The purpose of this section is for the student to get used to Riemann Sums applied to three-dimensional objects. All volumes in this section are non-rotational.
- (click to expand)
-
- Geometry
- Similar Triangles: The cross-sectional dimension is related to its position along the axis by recognizing similar triangles and equating ratios; in Example 1.2.1 the proportion \(\frac{s}{a} = \frac{x}{h}\) gives \(s = \frac{ax}{h}\), and Checkpoint 1.2.1 uses the same idea for the cone.
- Volumes and Surface Areas of Common Shapes: The slicing method models each slice as a thin cylinder of volume \(A(x^*_i)\,\Delta x\), so understanding that a cylinder's volume is base-area times height (\(V = A \cdot h\)) is the conceptual anchor for the entire method; the section also recalls the sphere, cone, and pyramid volume formulas as known from prior courses.
- Quadratic Functions
- Graphing Quadratic Functions Using Properties: The base region in Examples 1.2.2 and 1.2.3 is bounded by the parabola \(f(x) = 4 - x^2\); visualizing this region (downward parabola, vertex \((0,4)\), \(x\)-intercepts at \(\pm 2\)) and its axis of symmetry is essential for setting up the integral and for exploiting the symmetry used in Example 1.2.2.
- Geometry
- (click to expand)
-
- Geometry
- Circles — Properties, Area, and Circumference: The semicircular cross-sections in Example 1.2.3 require the area \(\frac{1}{2}\pi r^2\), and deriving the cone's volume in Checkpoint 1.2.1 requires the circular cross-section area \(\pi r^2\).
- Area and Perimeter of Triangles and Quadrilaterals: Building the cross-sectional area function \(A(x)\) uses the area of a square in Example 1.2.1 (\(A = s^2\)) and the area of a triangle in Example 1.2.2 (\(A = \frac{1}{2}\,\text{base}\cdot\text{height}\)); the homework also draws on rectangle and other triangle areas.
- Solving Equations
- Solving Literal Equations: When the cross-sections are perpendicular to the \(y\)-axis (Example 1.2.3), the boundary \(y = 4 - x^2\) must be solved for \(x^2 = 4 - y\) so the area can be written in terms of \(y\).
- Conic Sections
- Ellipses: Homework problem #16 involves a solid with an elliptical base, which requires the standard equation of an ellipse to set up the cross-sectional area.
- Geometry
The following is a list of learning objectives for this section.
- Learning Objectives (click to expand)
-
- Determine the volume of a solid by integrating a cross-section (the slicing method).
In the preceding section, we used definite integrals to find the area between two curves. In this section, we use definite integrals to find volumes of three-dimensional solids. We start by developing a basic approach based on slicing.
Volume and the Slicing Method
Just as area is the numerical measure of a two-dimensional region, volume is the numerical measure of a three-dimensional solid. Most of us have computed volumes of solids by using basic geometric formulas. The volume of a rectangular solid, for example, can be computed by multiplying length, width, and height: \(V = lwh\). The following formulas for volumes have been introduced in previous courses.
- a sphere\[V_{\text{sphere}}=\dfrac{4}{3} \pi r^3,\nonumber\]
- a cone\[V_{\text{cone}}=\dfrac{1}{3} \pi r^2h\nonumber\]
- and a pyramid\[V_{\text{pyramid}}=\dfrac{1}{3}Ah\nonumber\]
Although some of these formulas were derived using Geometry alone, all these formulas can be obtained using integration.
We can also calculate the volume of a cylinder. Although most of us think of a cylinder as having a circular base, such as a soup can or a metal rod, in mathematics, the word cylinder has a more general meaning. We first need to define some vocabulary to discuss cylinders in this more general context.
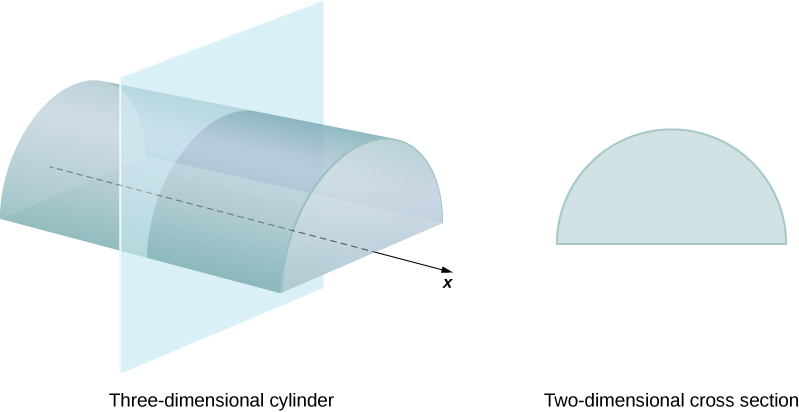
We define a solid's cross-section as the intersection of a plane with the solid. A cylinder is defined as any solid that can be generated by translating a plane region along a line perpendicular to the region called the axis of the cylinder. Thus, all cross-sections perpendicular to the axis of a cylinder are identical. The solid shown in Figure \(\PageIndex{1}\) is an example of a cylinder with a noncircular base. To calculate the volume of a cylinder, we multiply the area of the cross-section by the height of the cylinder: \(V=A \cdot h\). In the case of a right circular cylinder (soup can), this becomes \(V= \pi r^2h\).
If a solid does not have a constant cross-section (and it is not one of the other basic solids), we may not have a formula for its volume. In this case, we can use a definite integral to calculate the volume of the solid. We do this by slicing the solid into pieces, estimating the volume of each slice, and then adding those estimated volumes together. The slices should all be parallel to one another, and when we put all the slices together, we should get the whole solid. Consider, for example, the solid \(S\) shown in Figure \(\PageIndex{2}\), extending along the \(x\)-axis.

We want to divide \(S\) into slices perpendicular to the \(x\)-axis. As we see later in the chapter, there may be times when we want to slice the solid in some other direction—say, with slices perpendicular to the \(y\)-axis. The decision of which way to slice the solid is vital. If we make the wrong choice, the computations can get quite messy. Later in the chapter, we examine some of these situations in detail and decide which way to slice the solid. For the purposes of this section, however, we use slices perpendicular to the \(x\)-axis.
Because the cross-sectional area is not constant, we let \(A(x)\) represent the cross-sectional area of the cross-section at point \(x\). Now let \(P=\{x_0,x_1,\ldots,x_n\}\) be a regular partition of \([a,b]\), and for \(i=1,2,\ldots,n\), let \(S_i\) represent the slice of \(S\) stretching from \(x_{i-1}\) to \(x_i\). The following figure shows the sliced solid with \(n=3\).

Finally, for \(i=1,2,\ldots,n\), let \(x^*_i\) be an arbitrary point in \([x_{i-1},x_i]\). Then the volume of slice \(S_i\) can be estimated by \(V(S_i) \approx A(x^*_i)\, \Delta x\). Adding these approximations together, we see the volume of the entire solid \(S\) can be approximated by\[V(S) \approx \sum_{i=1}^nA(x^*_i)\, \Delta x.\nonumber\]By now, we can recognize this as a Riemann sum, and our next step is to take the limit as \(n \to \infty \). Then we have\[V(S)=\lim_{n \to \infty}\sum_{i=1}^nA(x^*_i)\, \Delta x= \int _a^b A(x)\,dx.\nonumber\]The technique we have just described is called the slicing method. To apply it, we use the following strategy.
- Examine the solid and determine the shape of a cross-section of the solid. It is often helpful to draw a picture if one is not provided.
- Determine a formula for the area of the cross-section.
- Integrate the area formula over the appropriate interval to get the volume.
This section assumes the slices are perpendicular to the \(x\)-axis. Therefore, the area formula is in terms of \(x\), and the limits of integration lie on the \(x\)-axis. However, the problem-solving strategy shown here is valid regardless of how we choose to slice the solid.
We know from Geometry that the formula for the volume of a pyramid is \(V=\frac{1}{3}Ah\). If the pyramid has a square base, this becomes \(V=\frac{1}{3}a^2h\), where \(a\) denotes the length of one side of the base. We are going to use the slicing method to derive this formula.
- Solution
-
We want to apply the slicing method to a pyramid with a square base. To set up the integral, consider the pyramid shown in Figure \(\PageIndex{4}\), oriented along the \(x\)-axis.
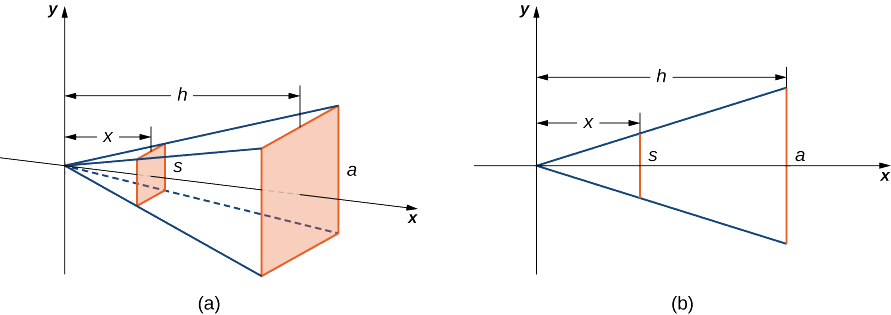
Figure \(\PageIndex{4}\): (a) A pyramid with a square base is oriented along the \(x\)-axis. (b) A two-dimensional view of the pyramid is seen from the side. We first want to determine the shape of a cross-section of the pyramid. We know the base is a square, so the cross-sections are squares as well. Now, we want to determine a formula for the area of one of these cross-sectional squares. Looking at Figure \(\PageIndex{4}\)(b), and using a proportion, since these are similar triangles, we have\[\dfrac{s}{a}=\dfrac{x}{h}\nonumber\]or\[s=\dfrac{ax}{h}.\nonumber\]Therefore, the area of one of the cross-sectional squares is\[A(x)=s^2=\left(\dfrac{ax}{h}\right)^2.\nonumber\]Then we find the volume of the pyramid by integrating from \(0\) to \(h\):\[V= \int _0^hA(x)\,dx= \int _0^h\left(\dfrac{ax}{h}\right)^2\,dx=\dfrac{a^2}{h^2} \int _0^hx^2\,dx=\Big[\dfrac{a^2}{h^2}\left(\dfrac{1}{3}x^3\right)\Big]\bigg|^h_0=\dfrac{1}{3}a^2h.\nonumber\]This is the formula we were looking for.
Use the slicing method to derive the formula \[V=\frac{1}{3} \pi r^2h\nonumber\] for the volume of a circular cone.
- Hint
-
Use similar triangles, as in Example \(\PageIndex{1}\).
While Example \(\PageIndex{1}\) is a shape we are familiar with, it behooves us to experiment with finding the volume of a solid having a more challenging design. For this discussion, we consider solids having a base region defined by a given boundary. This boundary is often an area between two functions on a specified interval, however, it can be a region bounded by a non-functional curve such as a conic section. Onto this base region, we will slide in cross-sectional slices perpendicular to the base (see the Interactive Element below).
Description: This Geogebra applet allows you to visualize how a solid of known cross-sections is generated by placing cross-sectional slices perpendicular to the \(x\)-axis on a base defined by the boundary between two functions (red and blue) from \(x = 0\) to \(X\), where you can adjust \(X\) using the bottom slider.
Interact: Adjust the rightmost boundary, \(X\), of the region to whatever value you want, select a single cross-sectional shape (square, equilateral triangle, or semi-circle), increase \(n\) to a decent number of slices to help you visualize what is going on, and (finally) use your mouse to adjust the graph of the right side of the applet to see the resulting solid.
Let's take a look at two examples.
Find the volume of the solid with base region bounded by \(f(x) = 4 - x^2\) and the \(x\)-axis, where the cross-sections perpendicular to the \(x\)-axis are isosceles right triangles with hypotenuse in the base region.
- Solution
-
We begin by drawing a top-down view of the base region, including the \(i^{\text{th}}\) slice (see Figure \(\PageIndex{5}\) below).

Figure \(\PageIndex{5}\): A top-down view of the base region along with the \(i^{\text{th}}\) slice. It will also be beneficial to sketch a side view of the \(i^{\text{th}}\) slice (see Figure \(\PageIndex{6}\) below).

Figure \(\PageIndex{6}\): A side view of the \(i^{\text{th}}\) slice. The following Interactive Element might help you visualize the solid whose cross-sections perpendicular to the \(x\)-axis are isosceles right triangles.
Interact: Click and drag empty space to rotate; use the middle mouse scroll wheel to zoom in and out; click the blue "curve" button in the function list to reveal the triangular slice; click the magenta marker to step the triangular slice across the solid—it sweeps and repeats.
Observation: Every cross-section perpendicular to the \(x\)-axis is an isosceles right triangle whose hypotenuse \(4-x^2\) is widest at the center and vanishes at \(x=\pm 2\); the symmetry about \(x=0\) is why the volume runs from \(0\) to \(2\) and is doubled.
The volume of this \(i^{\text{th}}\) slice can be found using the fact that the surface area of a triangle is one-half the product of the base and the height. Hence,\[V_i = \dfrac{1}{2} \left(\text{base}\right)\left(\text{height}\right) \Delta x = \dfrac{1}{2} \left( f(x_i^*) - 0 \right) \left(\text{height}\right) \Delta x = \dfrac{1}{2} \left( 4 - (x_i^*)^2 \right) \left(\text{height}\right) \Delta x.\nonumber\]To determine the height of this \(i^{\text{th}}\) slice, we use the fact that the base has length \(4 - (x_i^*)^2\), which means half of the base has length \(\frac{1}{2}\left(4 - (x_i^*)^2\right)\). Since the triangle is an isosceles right triangle, the height equals this half-base length. Hence,\[V_i = \dfrac{1}{4} \left( 4 - (x_i^*)^2 \right)^2 \Delta x.\nonumber\]From Figure \(\PageIndex{5}\), we can see that symmetry can be used so that we only need to add up the volumes of the slices starting at \(x = 0\) and ending at \(x = 2\). We double this result to approximate the total area. That is,\[V \approx 2 \sum_{i = 0}^n V_i = \dfrac{1}{2} \sum_{i = 0}^n \left( 4 - (x_i^*)^2 \right)^2 \Delta x.\nonumber\]Taking the limit as \(n \to \infty\), we get\[\begin{array}{rcl} V & = & \dfrac{1}{2} \displaystyle \int_0^2 (4 - x^2)^2 \, dx \\ \\ & = & \dfrac{1}{2} \displaystyle \int_0^2 16 - 8 x^2 + x^4 \, dx \\ \\ & = & \dfrac{1}{2} \left( 16x - \dfrac{8}{3} x^3 + \dfrac{1}{5} x^5 \right) \bigg|_0^2 \\ \\ & = & \dfrac{1}{2} \left( 32 - \dfrac{64}{3} + \dfrac{32}{5} \right) \\ \\ & = & \dfrac{128}{15} \, \text{cubic units} \\ \end{array}\nonumber\]
Find the volume of the solid with base region bounded by \(f(x) = 4 - x^2\) and the \(x\)-axis, where the cross-sections perpendicular to the \(y\)-axis are semi-circles.
- Solution
-
Just as we did in Example \(\PageIndex{2}\), we begin by sketching a top-down view of the base region with the \(i^{\text{th}}\) slice, and a side view of the \(i^{\text{th}}\) slice (see Figure \(\PageIndex{7}\)).
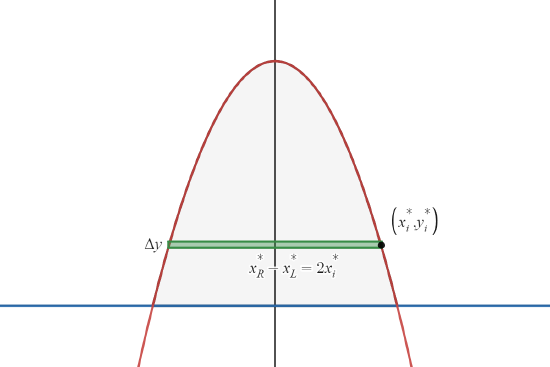

Figure \(\PageIndex{7}\)A: A top-down view of the base region along with the \(i^{\text{th}}\) slice.
Figure \(\PageIndex{7}\)B: A side view of the \(i^{\text{th}}\) slice.The following Interactive Element might help you visualize the solid whose cross-sections perpendicular to the \(y\)-axis are semi-circles.
Interact: Click and drag empty space to rotate; click the purple marker to step the semicircular slice through the solid — it sweeps bottom-to-top and repeats.
Observation: Every cross-section perpendicular to the \(y\)-axis is a semicircle whose radius \(\sqrt{4-y}\) shrinks from \(2\) at the base \((y=0)\) to \(0\) at the top \((y=4)\), so the volume integrates \(\tfrac{1}{2}\pi(4-y)\) with respect to \(y\).
The volume of the \(i^{\text{th}}\) slice is\[V_i = \dfrac{1}{2} \pi \left(r_i^*\right)^2 \Delta y = \dfrac{1}{2} \pi \left( x_i^* \right)^2 \Delta y.\nonumber\]Using the relation \(y_i^* = 4 - \left(x_i^*\right)^2\), we get\[V_i = \dfrac{1}{2} \pi \left( 4 - y_i^* \right) \Delta y.\nonumber\]Therefore\[\begin{array}{rcl} V & = & \displaystyle \lim_{n \to \infty} \sum_{i = 0}^n V_i \\ \\ & = & \displaystyle \int_{y = 0}^{y = 4} \dfrac{1}{2} \pi \left( 4 - y \right) \, dy \\ \\ & = & \dfrac{\pi}{2} \left( 4y - \dfrac{y^2}{2} \right) \bigg|_{y = 0}^{y = 4} \\ \\ & = & 4 \pi \, \text{cubic units} \\ \end{array}\nonumber\]