

6.1: Problem Set
- Page ID
- 24166
\( \newcommand{\vecs}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\( \newcommand{\vecd}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash {#1}}} \)
\( \newcommand{\dsum}{\displaystyle\sum\limits} \)
\( \newcommand{\dint}{\displaystyle\int\limits} \)
\( \newcommand{\dlim}{\displaystyle\lim\limits} \)
\( \newcommand{\id}{\mathrm{id}}\) \( \newcommand{\Span}{\mathrm{span}}\)
( \newcommand{\kernel}{\mathrm{null}\,}\) \( \newcommand{\range}{\mathrm{range}\,}\)
\( \newcommand{\RealPart}{\mathrm{Re}}\) \( \newcommand{\ImaginaryPart}{\mathrm{Im}}\)
\( \newcommand{\Argument}{\mathrm{Arg}}\) \( \newcommand{\norm}[1]{\| #1 \|}\)
\( \newcommand{\inner}[2]{\langle #1, #2 \rangle}\)
\( \newcommand{\Span}{\mathrm{span}}\)
\( \newcommand{\id}{\mathrm{id}}\)
\( \newcommand{\Span}{\mathrm{span}}\)
\( \newcommand{\kernel}{\mathrm{null}\,}\)
\( \newcommand{\range}{\mathrm{range}\,}\)
\( \newcommand{\RealPart}{\mathrm{Re}}\)
\( \newcommand{\ImaginaryPart}{\mathrm{Im}}\)
\( \newcommand{\Argument}{\mathrm{Arg}}\)
\( \newcommand{\norm}[1]{\| #1 \|}\)
\( \newcommand{\inner}[2]{\langle #1, #2 \rangle}\)
\( \newcommand{\Span}{\mathrm{span}}\) \( \newcommand{\AA}{\unicode[.8,0]{x212B}}\)
\( \newcommand{\vectorA}[1]{\vec{#1}} % arrow\)
\( \newcommand{\vectorAt}[1]{\vec{\text{#1}}} % arrow\)
\( \newcommand{\vectorB}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\( \newcommand{\vectorC}[1]{\textbf{#1}} \)
\( \newcommand{\vectorD}[1]{\overrightarrow{#1}} \)
\( \newcommand{\vectorDt}[1]{\overrightarrow{\text{#1}}} \)
\( \newcommand{\vectE}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash{\mathbf {#1}}}} \)
\( \newcommand{\vecs}[1]{\overset { \scriptstyle \rightharpoonup} {\mathbf{#1}} } \)
\(\newcommand{\longvect}{\overrightarrow}\)
\( \newcommand{\vecd}[1]{\overset{-\!-\!\rightharpoonup}{\vphantom{a}\smash {#1}}} \)
\(\newcommand{\ket}[1]{\left| #1 \right>}\)
\(\newcommand{\bra}[1]{\left< #1 \right|}\)
\(\newcommand{\braket}[2]{\left< #1 \vphantom{#2} \right| \left. #2 \vphantom{#1} \right>}\)
\(\newcommand{\braopket}[3]{\left< #1 \vphantom{#2}\vphantom{#3} \right| #2 \vphantom{#1}\vphantom{#3} \left| #3 \vphantom{#1}\vphantom{#2} \right>}\)
\(\newcommand{\qmvec}[1]{\mathbf{\vec{#1}}}\)
\(\newcommand{\op}[1]{\hat{\mathbf{#1}}}\)
\(\newcommand{\expect}[1]{\langle #1 \rangle}\)
\(\newcommand{\dfn}[1]{\emph{\textbf{#1}}}\)
EXERCISE \(\PageIndex{1}\)
Consider the \(C^{r}\), \(r \ge 1\), autonomous vector field on \(\mathbb{R}^2\):
\(\dot{x} = f(x)\),
with flow
\(\phi_{t}(\cdot)\),
and let \(x = \bar{x}\) denote a hyperbolic saddle type equilibrium point for this vector field. We denote the local stable and unstable manifolds of this equilibrium point by:
\(W_{loc}^{s}(\bar{x})\), \(W_{loc}^{u}(\bar{x})\),
respectively. The global stable and unstable manifolds of \(\bar{x}\) are defined by:
\(W^{s}(\bar{x}) \equiv \cup_{t \le 0} \phi_{t} (W_{loc}^{s}(\bar{x}))\),
\(W^{u}(\bar{x}) \equiv \cup_{t \ge 0} \phi_{t} (W_{loc}^{s}(\bar{x}))\),
(a) Show that \(W^{s}(\bar{x})\) and \(W^{u}(\bar{x})\) are invariant set.
(b) Suppose that \(p \in W^{s}(\bar{x})\), show that \(\phi_{t}(p) \rightarrow \bar{x}\) at an exponential rate as \(t \rightarrow \infty\).
(c) Suppose that \(p \in W^{u}(\bar{x})\), show that \(\phi_{t}(p) \rightarrow \bar{x}\) at an exponential rate as \(t \rightarrow -\infty\).
EXERCISE \(\PageIndex{2}\)
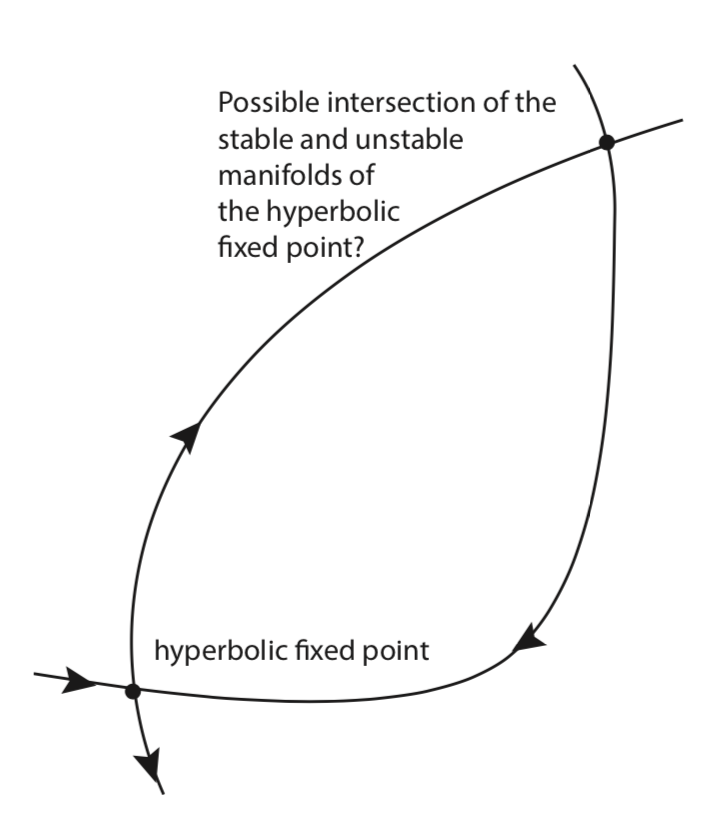
Consider the \(C^{r}, r \ge 1\), autonomous vector field on \(\mathbb{R}^2\) having a hyperbolic saddle point. Can its stable and unstable manifolds intersect at an isolated point (which is not a fixed point of the vector field) as shown in figure 2?
EXERCISE \(\PageIndex{3}\)
Consider the following autonomous vector field on the plane:
\(\dot{x} = \alpha x\),
\[\dot{y} = \beta y + \gamma x^{n+1}, \label{6.42}\]
where \(\alpha < 0\), \(\beta > 0\), \(\gamma\) is a real number, and n is a positive integer.
- Show that the origin is a hyperbolic saddle point.
- Compute and sketch the stable and unstable subspaces of the origin.
- Show that the stable and unstable subspaces are invariant under the linearized dynamics.
- Show the the flow generated by this vector field is given by:
\(x(t, x_{0}) = x_{0}e^{\alpha t}\),
\(y(t, x_{0}, y_{0}) = e^{\beta t}(y_{0} - \frac{\gamma x_{0}^{n+1}}{\alpha (n+1) - \beta}) + (\frac{\gamma x_{0}^{n+1}}{\alpha (n+1) - \beta}) e^{\alpha (n+1)t}\)
- Compute the global stable and unstable manifolds of the origin from the flow.
- Show that the global stable and unstable manifolds that you have computed are invariant.
- Sketch the global stable and unstable manifolds and discuss how they depend on g and n.
EXERCISE \(\PageIndex{4}\)
Suppose \(\dot{x} = f(x), x \in \mathbb{R}^n\) is a \(C^r\) vector field having a hyperbolic fixed point, \(x = x_{0}\), with a homoclinic orbit. Describe the homoclinic orbit in terms of the stable and unstable manifolds of \(x_{0}\).
EXERCISE \(\PageIndex{5}\)
Suppose \(\dot{x} = f(x), x \in \mathbb{R}^n\) is a \(C^r\) vector field having hyperbolic fixed points, \(x = x_{0}\) and \(x_{1}\), with a heteroclinic orbit connecting \(x_{0}\) and \(x_{1}\). Describe the heteroclinic orbit in terms of the stable and unstable manifolds of \(x_{0}\) and \(x_{1}\).